Exercise - Deploy an Azure RTOS real-time sensor application to monitor the room environment
In this exercise, you'll deploy the Eclipse ThreadX (formerly Azure RTOS ThreadX) real-time application included with this lab to your Azure Sphere device. The lab folder is named Lab_6_AzureRTOS_Environment, reflecting the original Azure RTOS branding. Note: the RTOS used by this lab — Azure RTOS ThreadX — has since been contributed to the Eclipse Foundation and is now known as Eclipse ThreadX. The Microsoft Learn pages used here remain valid for the version distributed with this lab.
Important
Before you start, verify that the Azure Sphere SDK, Azure Sphere Visual Studio Code extension, CMake, Ninja, and the GNU Arm Embedded toolchain are installed; the device is connected over USB, claimed to your Azure Sphere catalog, and has network access. Sideloading and debugging require the device to have the appDevelopment capability. Real-time core debugging also requires RT-core debugging support. With Azure Sphere Integrated, sign in with az login, then run the following command. On Windows, run it from an elevated PowerShell or Windows Command Prompt because the RT-core debugging option installs USB debugging drivers.
az sphere device enable-development --enable-rt-core-debugging --catalog <CatalogName> --resource-group <ResourceGroupName>
The command moves the device to a Development device group, which prevents cloud application updates from overwriting the app while you're debugging. After the command completes on Windows, close the elevated shell and continue from a non-elevated shell or Visual Studio Code. If you still use the Legacy CLI, use azsphere device enable-development --enable-rt-core-debugging.
Step 1: Delete the existing applications on the Azure Sphere
Peripheral ownership changes in this exercise: the environment sensor peripheral moves from the existing high-level application to the new real-time application. Concurrently loaded applications can't share a peripheral; when Azure Sphere loads an app, it configures pin multiplexing and core mapping and fails the load if another app already claims the same resource. Delete any existing sideloaded applications on the Azure Sphere device to avoid resource conflicts.
From the Windows PowerShell command line or Linux Terminal, delete the existing application by running:
Azure Sphere Integrated CLI (current):
az sphere device sideload deleteLegacy CLI (still supported):
azsphere device sideload delete
Restart the Azure Sphere device to reset peripherals and core mappings before you deploy the RTApp. From the Windows PowerShell command line or Linux Terminal, run:
Azure Sphere Integrated CLI (current):
az sphere device restartLegacy CLI (still supported):
azsphere device restart
Step 2: Open the project
Start Visual Studio Code.
From the menu, click File, then Open Folder.
Open the Azure-Sphere lab folder.
Open the Lab_6_AzureRTOS_Environment folder.
Click Select Folder or the OK button to open the project.
If you installed the Visual Studio Code Peacock extension, then Visual Studio Code will turn red. We will be connecting two instances of Visual Studio Code to the Azure Sphere. The red colored instance is connected to the real-time core.
Step 3: Set your developer board configuration
These labs support developer boards from AVNET and Seeed Studio. You need to set the configuration that matches your developer board.
The default developer board configuration is for the Avnet Azure Sphere Starter Kit Revision 1. If you have this board, there's no additional configuration required.
Open the CMakeLists.txt file.
Add a
#at the beginning of the set Avnet line to disable it.Uncomment the
setcommand that corresponds to your Azure Sphere device developer board.set(AVNET TRUE "AVNET Azure Sphere Starter Kit Revision 1 ") # set(AVNET_REV_2 TRUE "AVNET Azure Sphere Starter Kit Revision 2 ") # set(SEEED_STUDIO_RDB TRUE "Seeed Studio Azure Sphere MT3620 Development Kit (aka Reference Design Board or rdb)") # set(SEEED_STUDIO_MINI TRUE "Seeed Studio Azure Sphere MT3620 Mini Dev Board")Save the file. If CMake doesn't configure automatically, run CMake: Delete Cache and Reconfigure from the Visual Studio Code Command Palette so IntelliSense and the generated build files use the selected board.
Step 4: Deploy the Eclipse ThreadX (Azure RTOS) application to Azure Sphere
Ensure Visual Studio Code is using the Debug CMake build variant. The status bar might show CMake: [Debug]: Ready; if it doesn't, run CMake: Set Build Variant from the Command Palette and select Debug.
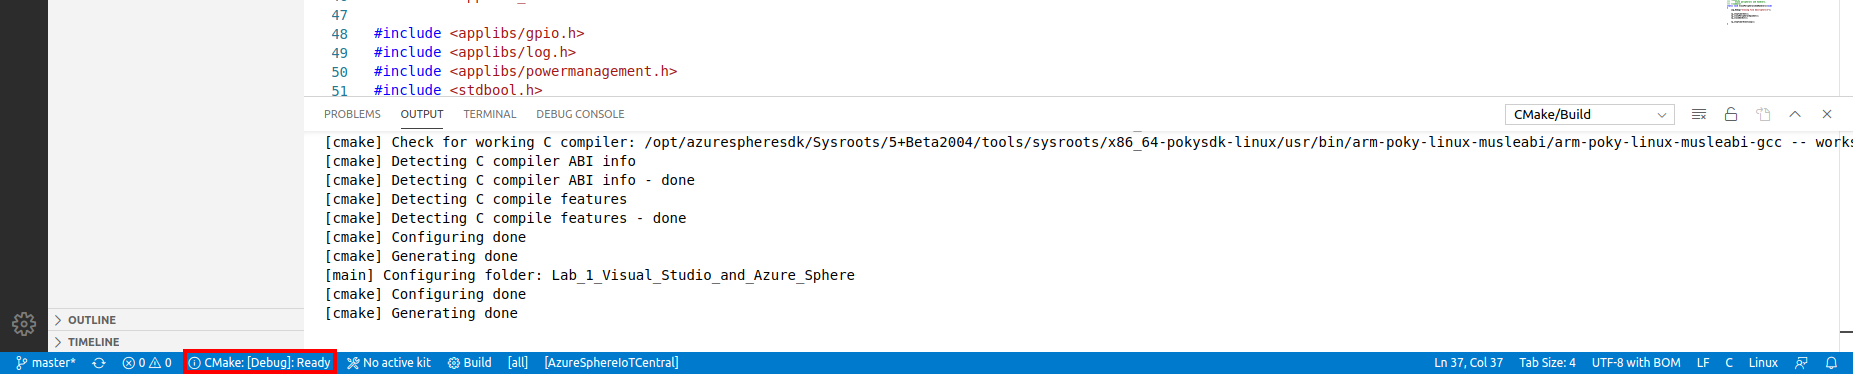
From Visual Studio Code, press F5 to build, deploy, start, and connect the remote debugger to the application now running on the Azure Sphere device.
Step 5: Debugging real-time core applications
You can debug the Eclipse ThreadX real-time application running on an Azure Sphere Cortex-M4F real-time core.
From Visual Studio Code, navigate to the demo_threadx directory, and open the demo_azure_rtos.c file.
Scroll down to the function named intercore_thread.
Note
Use Go to Symbol in Editor in Visual Studio Code. Use the keyboard shortcut Ctrl+Shift+O and start typing intercore_thread. You'll often see a function name listed twice in the drop-down. The first is the function prototype or forward signature declaration, and the second is the implementation of the function.
Set a breakpoint in the intercore_thread function on the line that reads switch (ic_control_block.cmd)
Note
You can learn how to set breakpoints from this Visual Studio Code Debugging article.
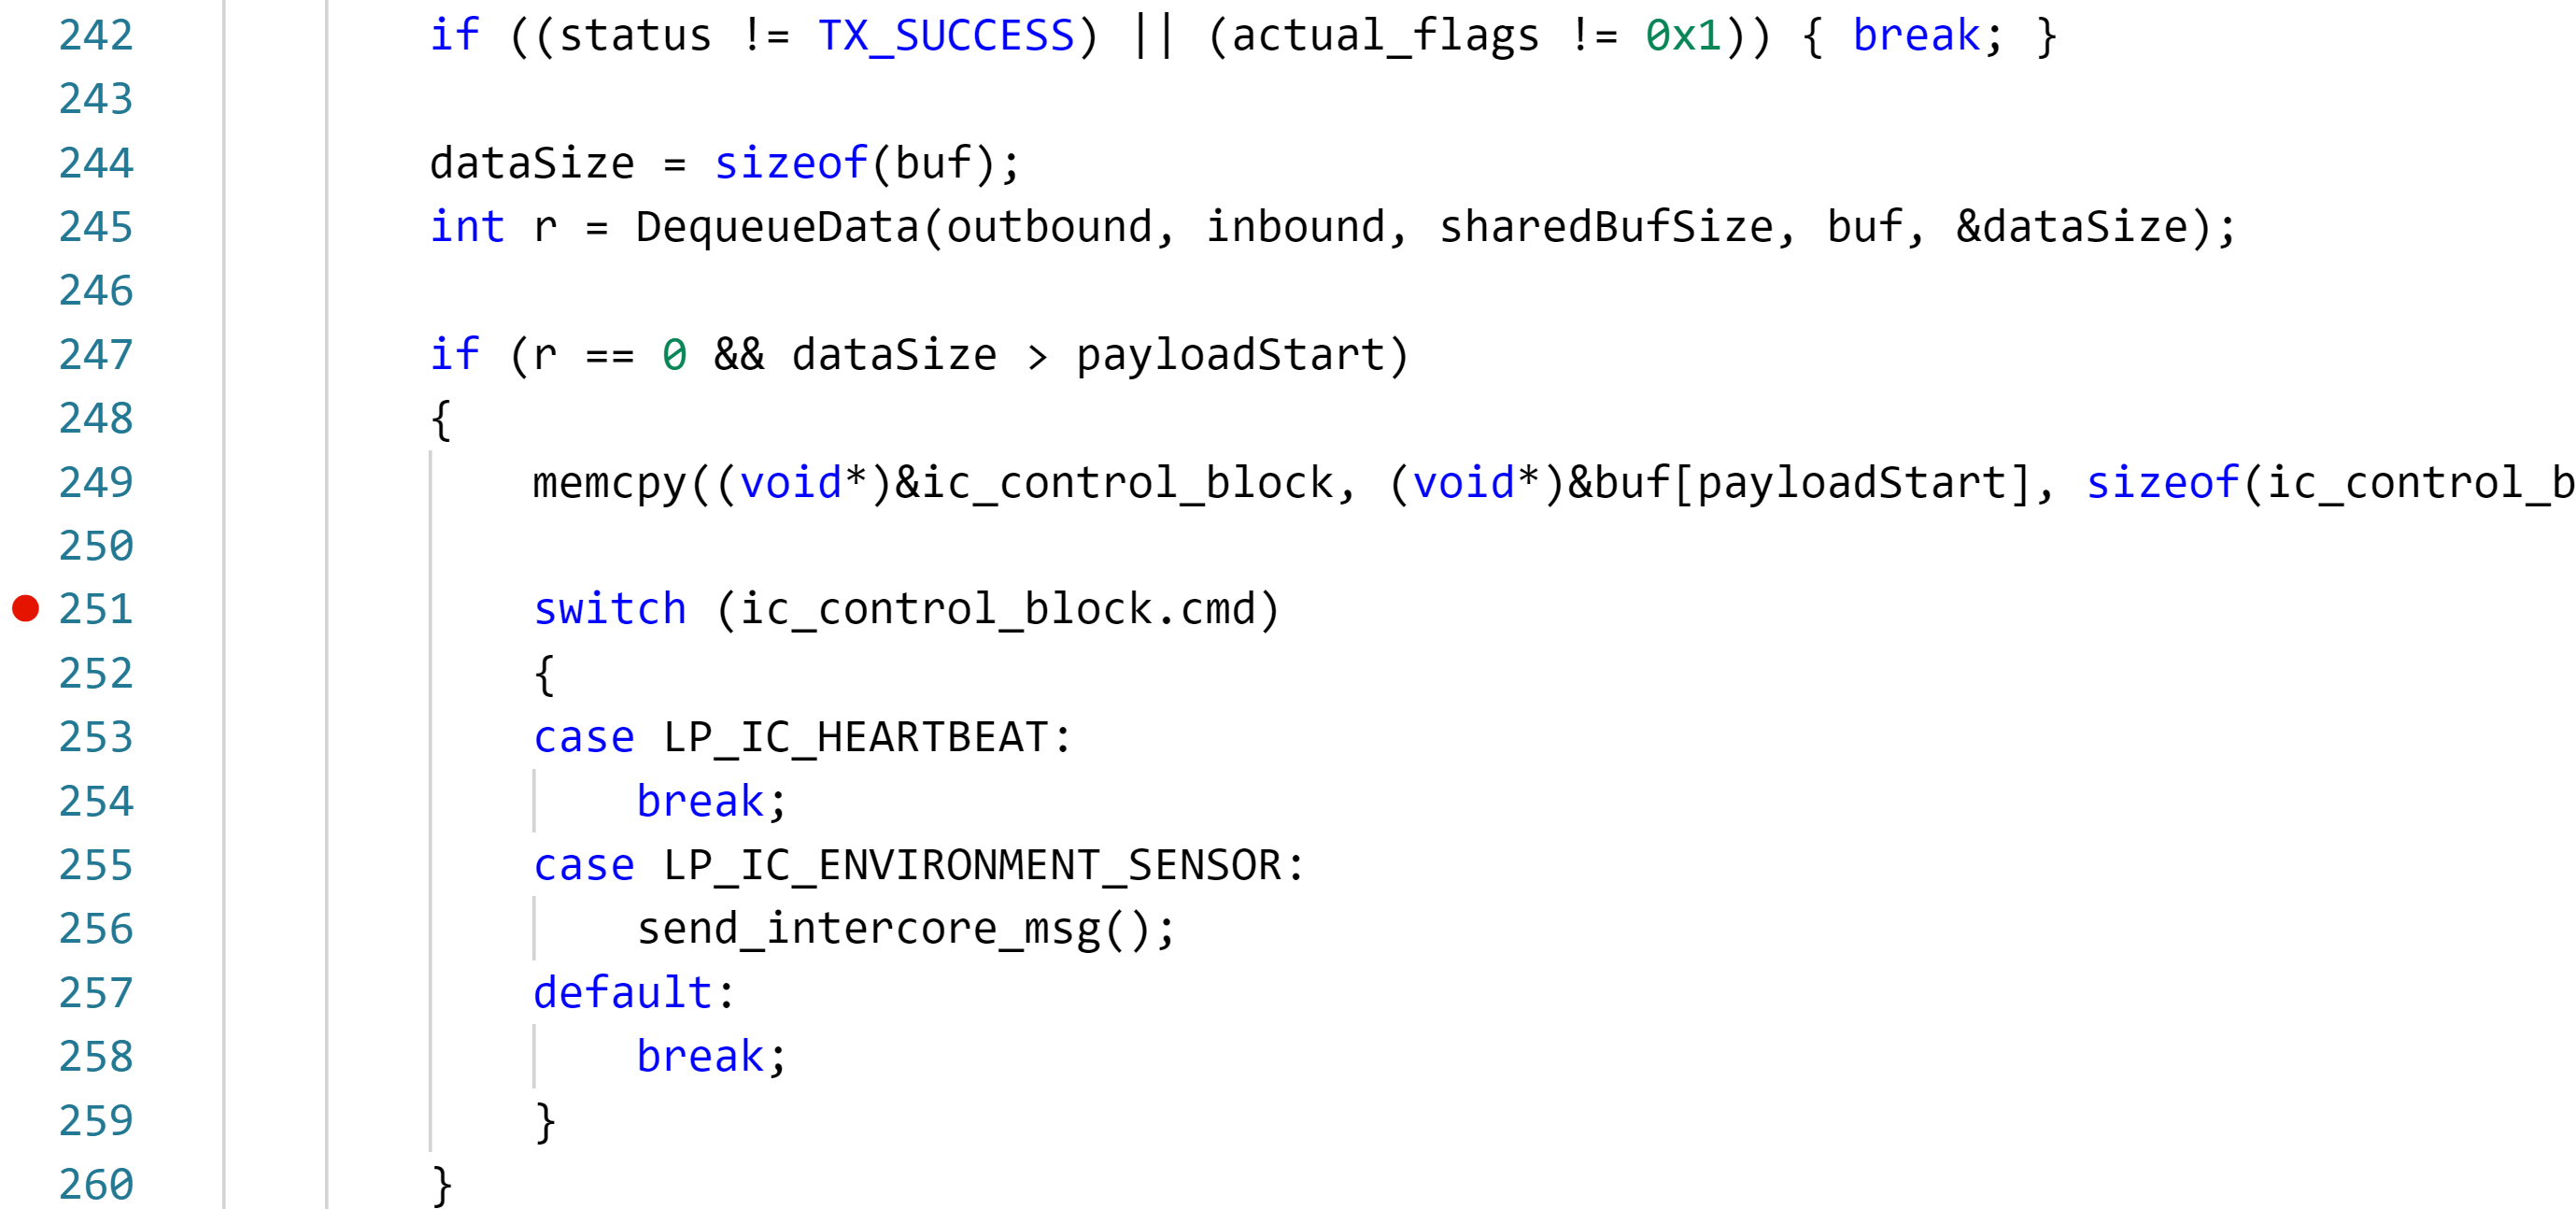
Leave Visual Studio Code and the app running with the breakpoint set. Next, you'll deploy a high-level application to the Cortex-A7 core that will request environment telemetry from the RTApp running on the Cortex-M4F core.
